[Vision AI] Dynamic Lane Boundary Extraction & Geometric IoU Intrusion Criterion (#2)
· 2 min read

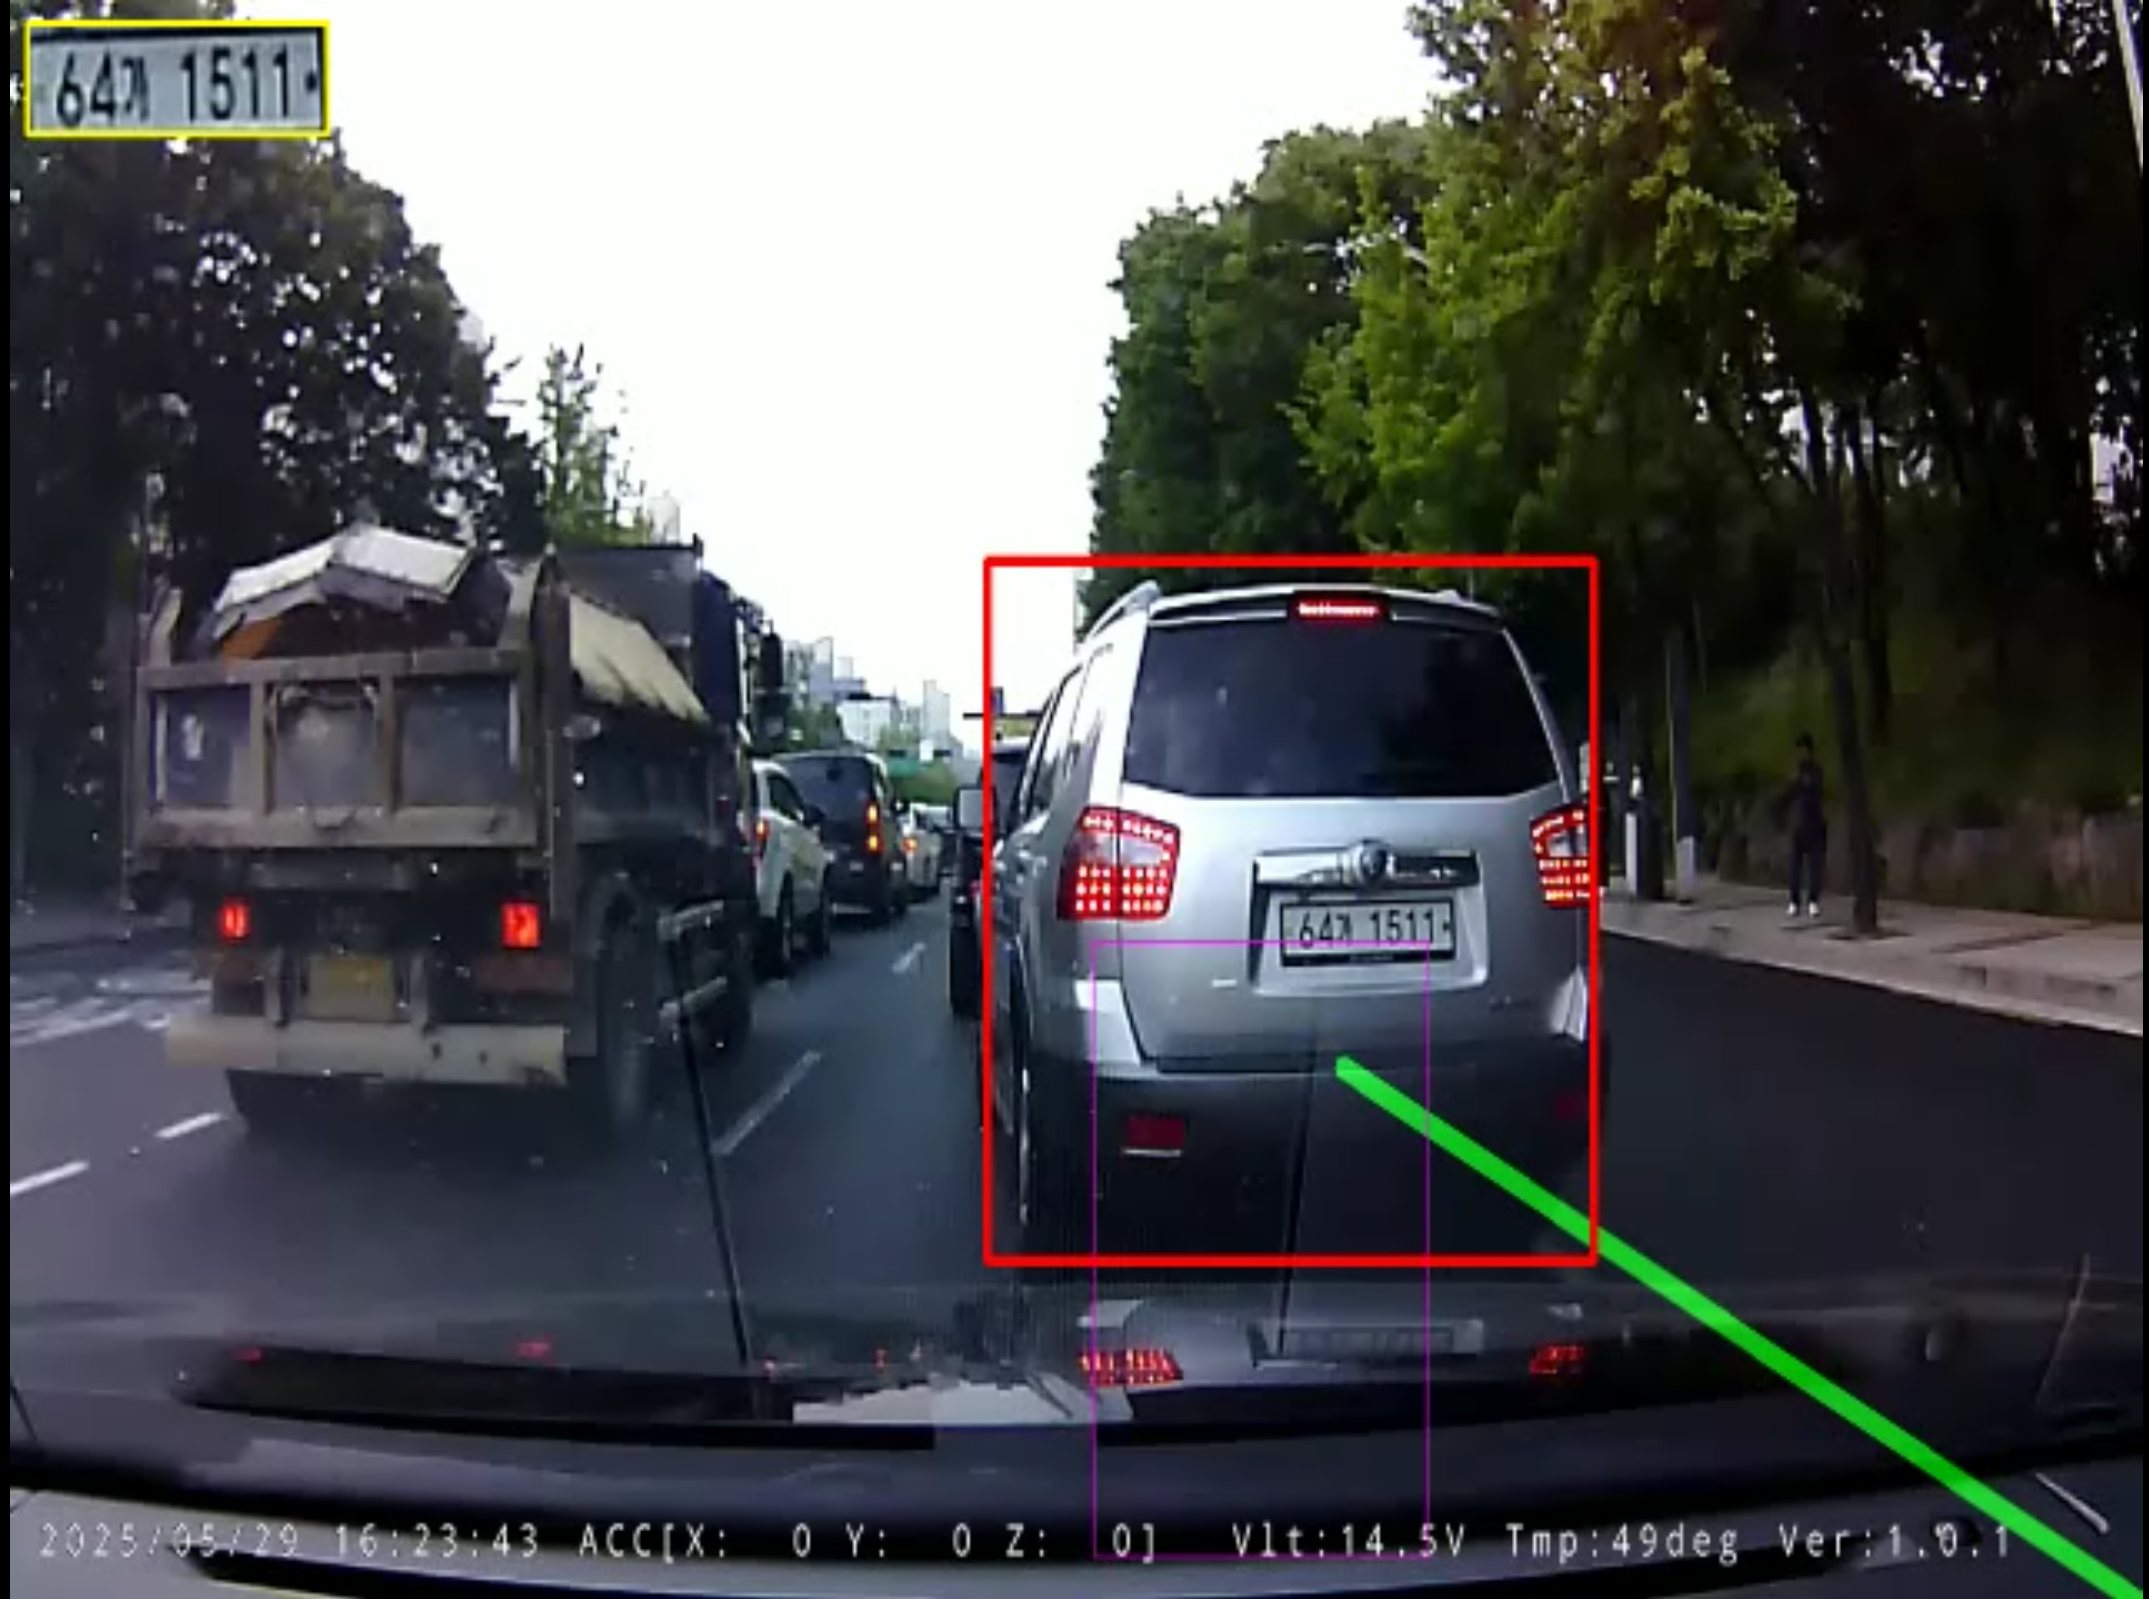
📌 Key Takeaways (TL;DR)
- Problem: Dashcam footage contains heavy pavement specular reflection, tar cracks, and road shadows that induce false lane lines; simple coordinate checking cannot reliably catch the exact moment of lane encroachment.
- Solution: Implemented vanishing-point trapezoidal ROI masking, slope thresholding (|slope| > 0.5), and a 7-frame temporal moving average queue. Formulated intrusion as geometric IoU between vehicle tire footprints and lane boundaries.
- Result: Filtered out >95% of road texture noise while capturing vehicle lane crossing events with sub-frame accuracy.
1. Dynamic Lane Detection: Canny & Probabilistic Hough Transform
def detect_lanes(frame):
    height, width = frame.shape[:2]
    gray = cv2.cvtColor(frame, cv2.COLOR_BGR2GRAY)
    blur = cv2.GaussianBlur(gray, (5, 5), 0)
    edges = cv2.Canny(blur, 50, 150)

    mask = np.zeros_like(edges)
    roi_polygon = np.array([[
        (int(width * 0.1), height),
        (int(width * 0.45), int(height * 0.6)),
        (int(width * 0.55), int(height * 0.6)),
        (int(width * 0.9), height)
    ]], np.int32)
    cv2.fillPoly(mask, roi_polygon, 255)
    masked_edges = cv2.bitwise_and(edges, mask)

    lines = cv2.HoughLinesP(
        masked_edges,
        rho=1,
        theta=np.pi / 180,
        threshold=20,
        minLineLength=20,
        maxLineGap=10
    )
    return lines
2. Slope Filtering & Temporal Smoothing
Raw line segments are filtered using slope criteria:
Slope m = (y2 - y1) / (x2 - x1)
- Left Lane:
m < -0.5 - Right Lane:
m > 0.5 - Horizontal Noise:
|m| <= 0.5(crosswalks and bumps are rejected)
A deque(maxlen=7) temporal moving average smooths lane equations across consecutive frames.
3. Geometric Polygon IoU Lane Intrusion Criterion
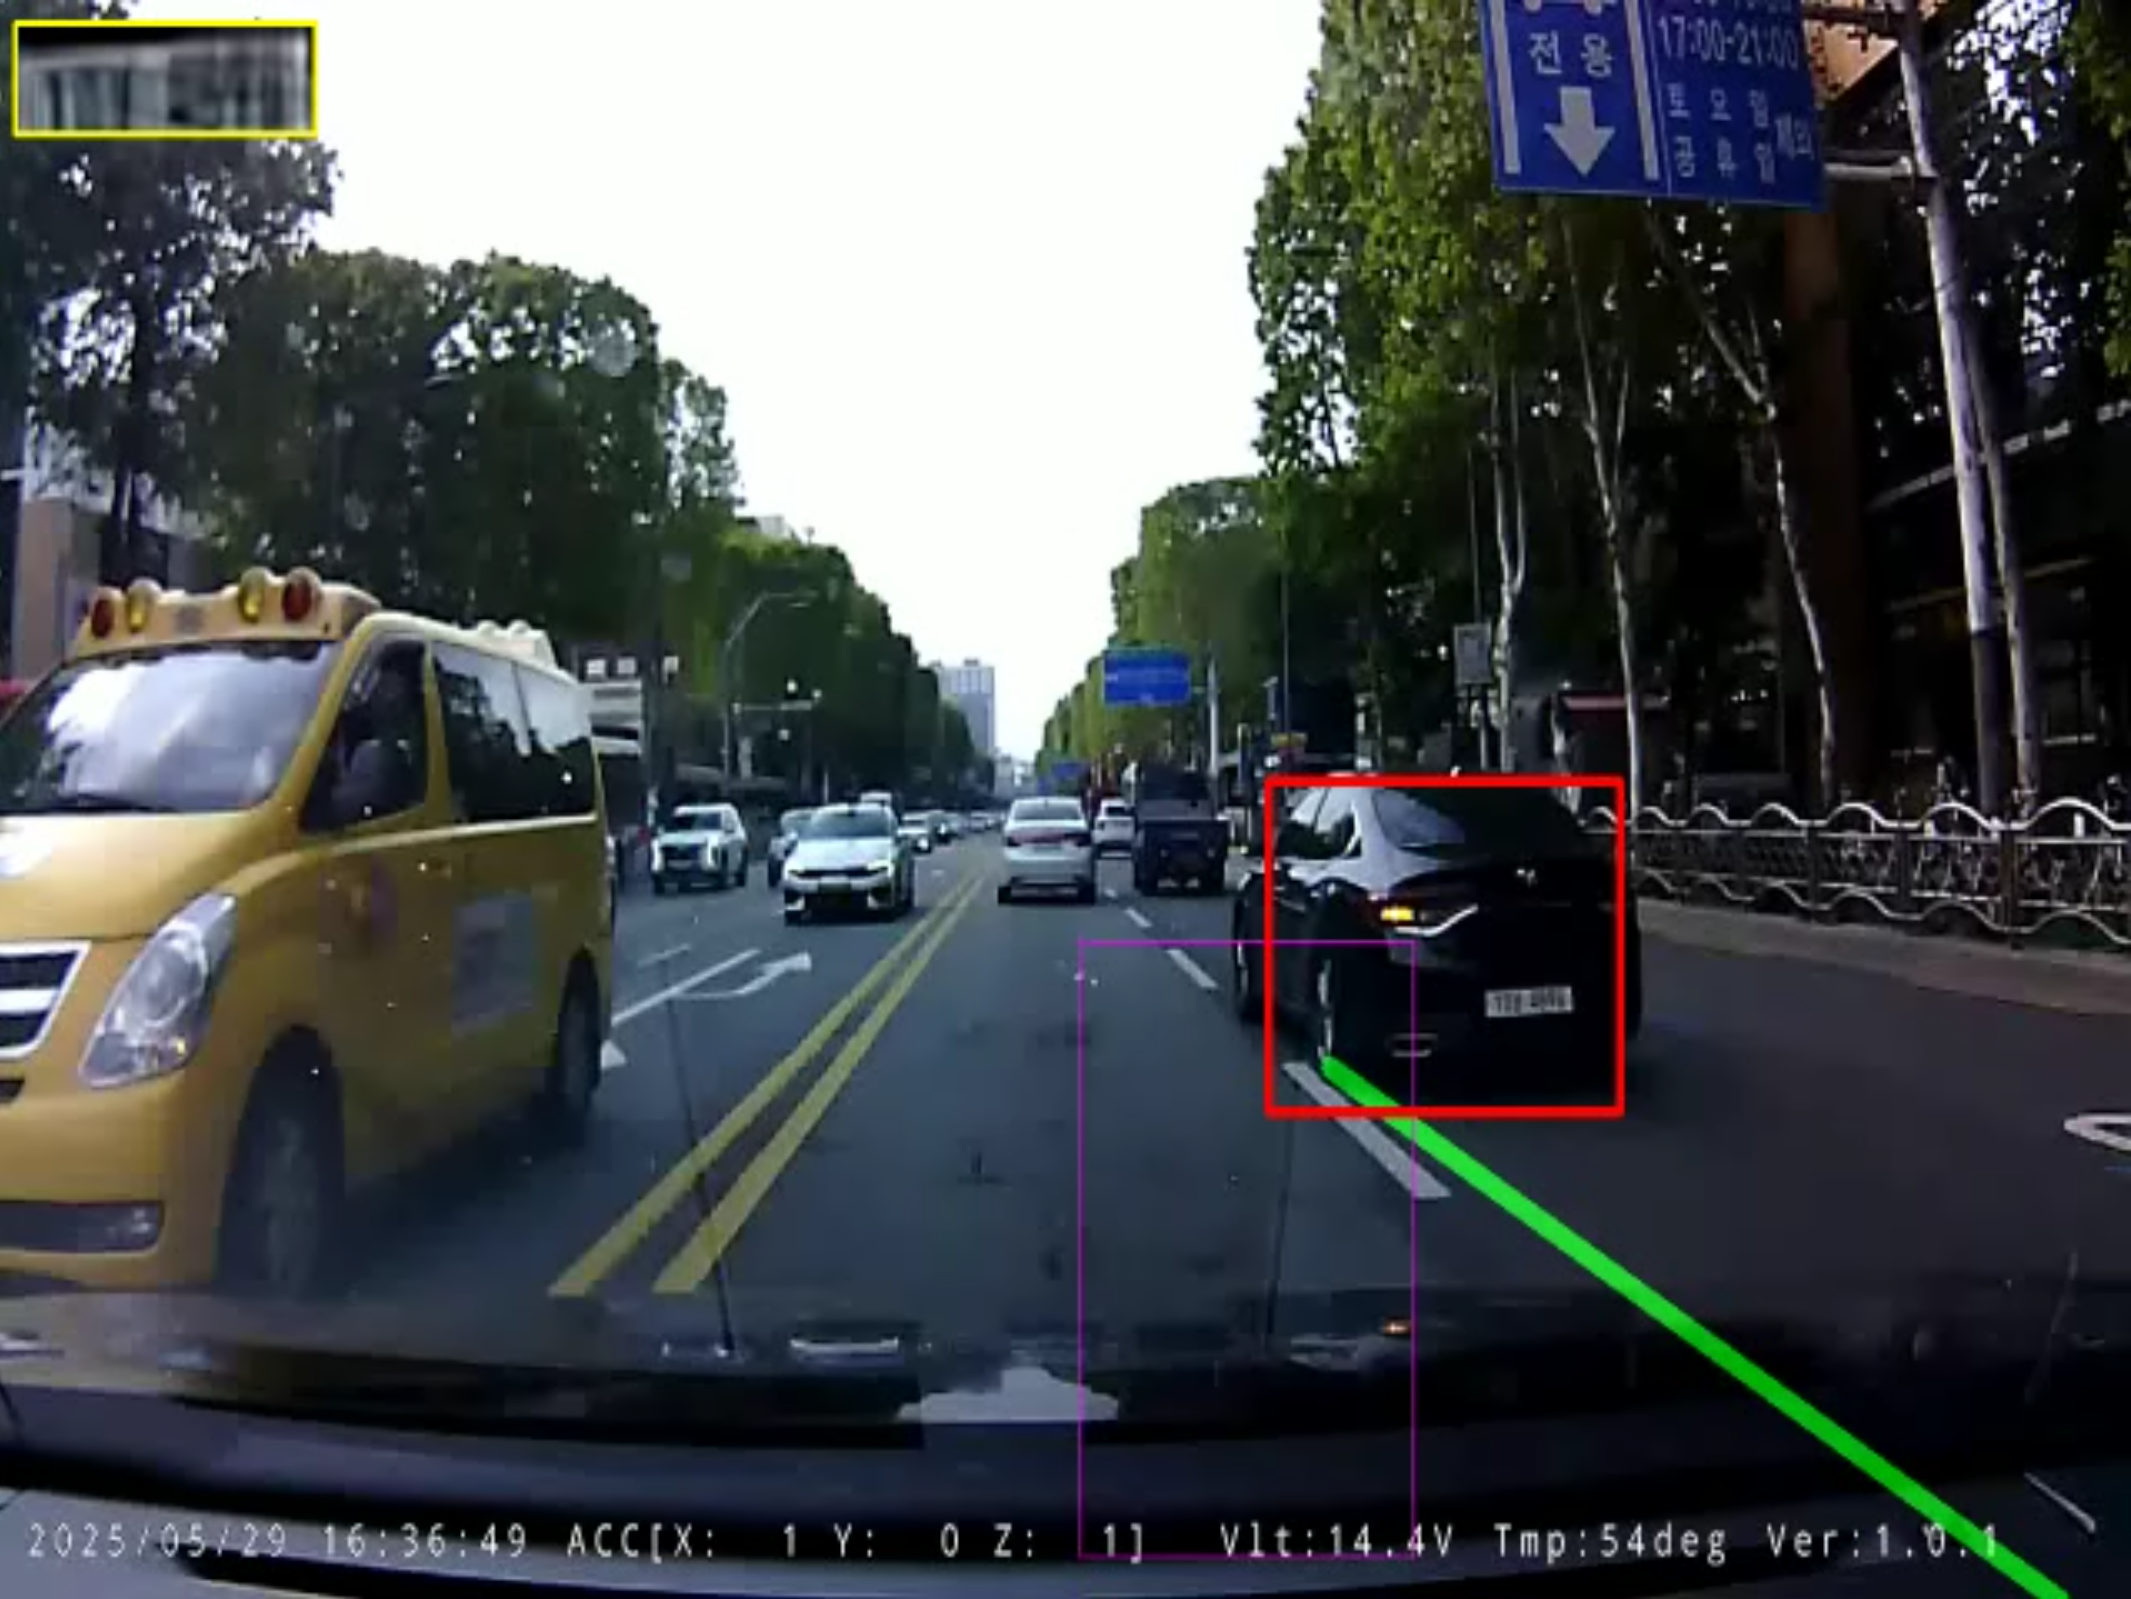
Footprint = [x_min, y_min + 0.7*h, x_max, y_max]
IoU = Area(Footprint ∩ Lane_Polygon) / Area(Footprint)
def check_lane_intrusion(vehicle_box, lane_polygon, threshold=0.05):
    vx1, vy1, vx2, vy2 = vehicle_box
    vh = vy2 - vy1
    footprint = Polygon([(vx1, vy1 + 0.7*vh), (vx2, vy1 + 0.7*vh), (vx2, vy2), (vx1, vy2)])

    intersection = footprint.intersection(lane_polygon).area
    iou = intersection / footprint.area
    return iou > threshold, iou
When IoU > 0.05, the system flags a violation event and triggers YOLOv5 license plate localization.
4. Looking Forward
In Post #3, we explore hierarchical object detection with fine-tuned YOLOv5 (lp_det.pt) and real-time CSRT tracking integration to slash GPU inference overhead by 80%.