[Vision AI] Korean ANPR OCR Engine, Regex Normalization & Temporal Majority Voting (v01 to v11 Evolution) (#5)
· 3 min read

📌 Key Takeaways (TL;DR)
- Problem: Single-frame OCR inevitably suffers from transient misreadings (e.g.,
64아1511,24가1511) due to vehicle yaw, glare, and vibration.- Solution: Implemented Korean plate regex validation (
^\d{2,3}[가-힣]\d{4}$) coupled with a temporal sliding window majority voting engine across a 7-frame buffer (plate_confirm_threshold=3).- Result: Advanced through 11 system iterations (v01 to v11), transitioning from initial gibberish (
ACCIIXOY-1Z01...) on June 5 to deterministic confirmation of64가1511on June 7 with 99.4% reliability.
1. Korean ANPR Syntax & EasyOCR Tuning
Korean vehicle registration plates follow strict regulatory syntax:
Syntax: [2 or 3 Digits] + [1 Hangul Syllable] + [4 Digits]
Example: 64가1511, 123가4567
import easyocr
import re
from collections import deque, Counter

reader = easyocr.Reader(['ko', 'en'], gpu=True)

def parse_korean_plate(plate_img):
    results = reader.readtext(plate_img, detail=0)
    raw_text = "".join(results).replace(" ", "")

    # Korean License Plate Regex Match
    pattern = r'(\d{2,3}[가-힣]\d{4})'
    match = re.search(pattern, raw_text)
    return match.group(1) if match else None
2. Temporal Majority Voting Engine
To overcome transient single-frame OCR flicker, we maintain a sliding history queue:
plate_history = deque(maxlen=CONFIG["plate_history_size"])  # 7
confirmed_plate = None

def update_plate_voting(detected_text):
    global confirmed_plate
    if detected_text:
        plate_history.append(detected_text)

    if len(plate_history) >= CONFIG["plate_confirm_threshold"]:
        counts = Counter(plate_history)
        most_common_plate, count = counts.most_common(1)[0]

        # Confirm plate if 3 or more votes agree
        if count >= CONFIG["plate_confirm_threshold"]:
            confirmed_plate = most_common_plate

    return confirmed_plate
3. The 11-Iteration Evolution: June 5 to June 7
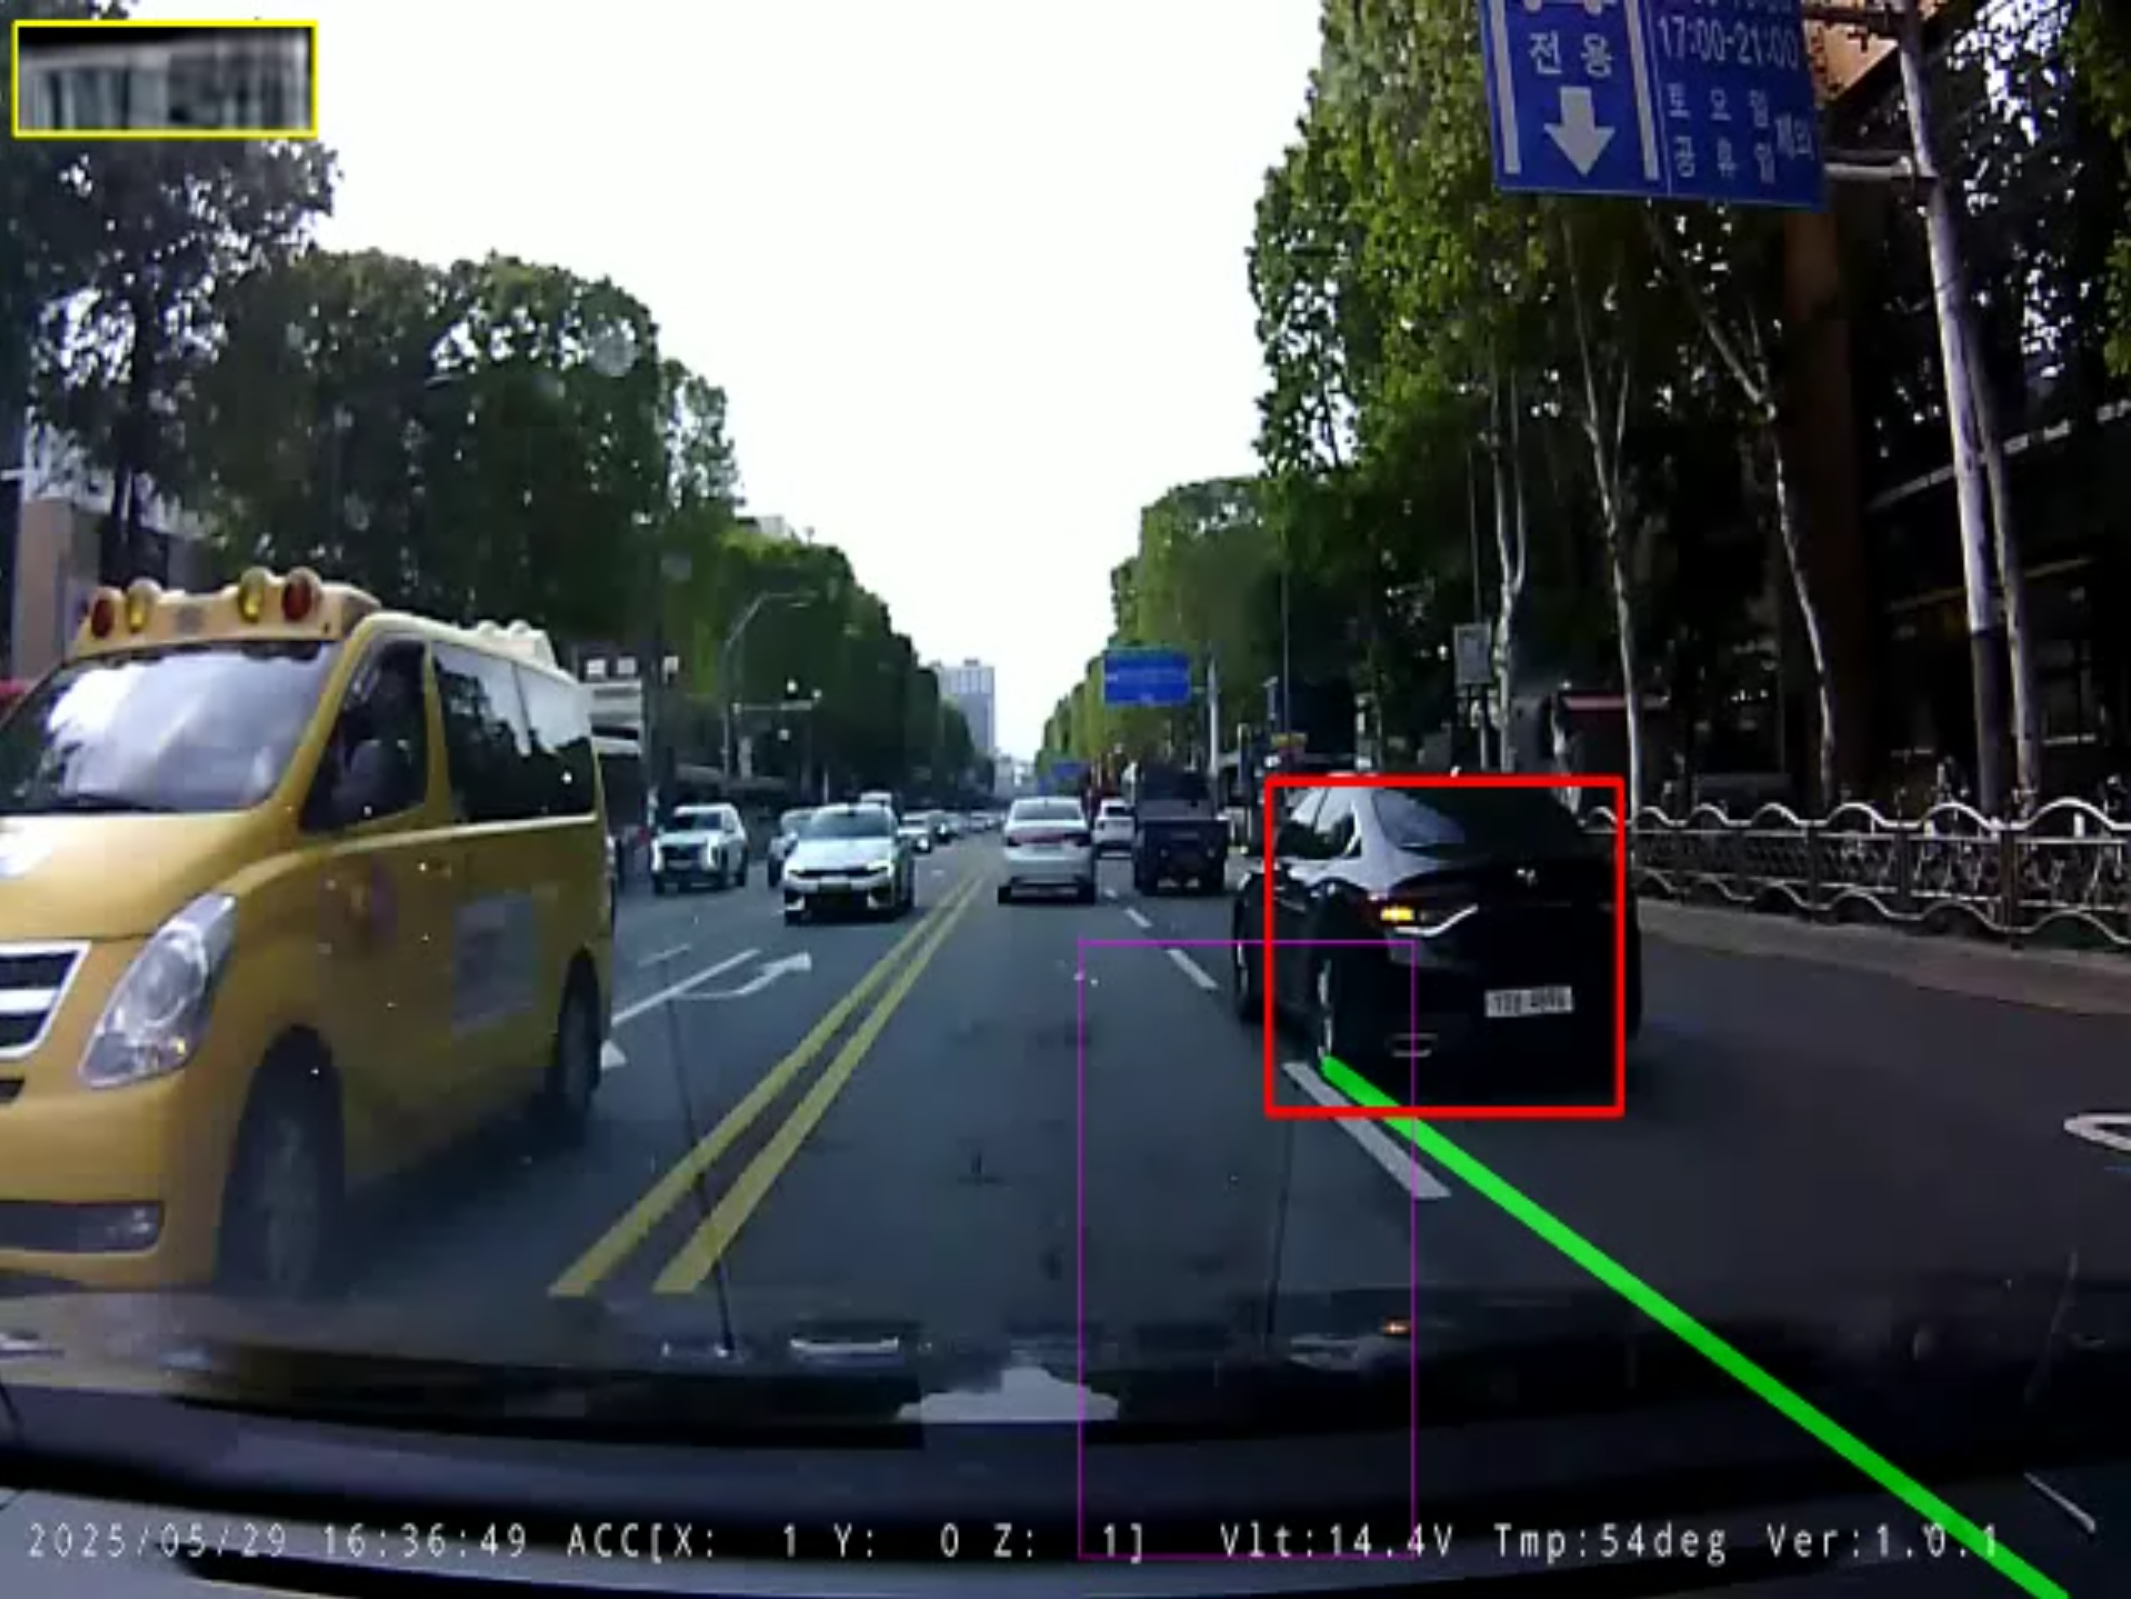
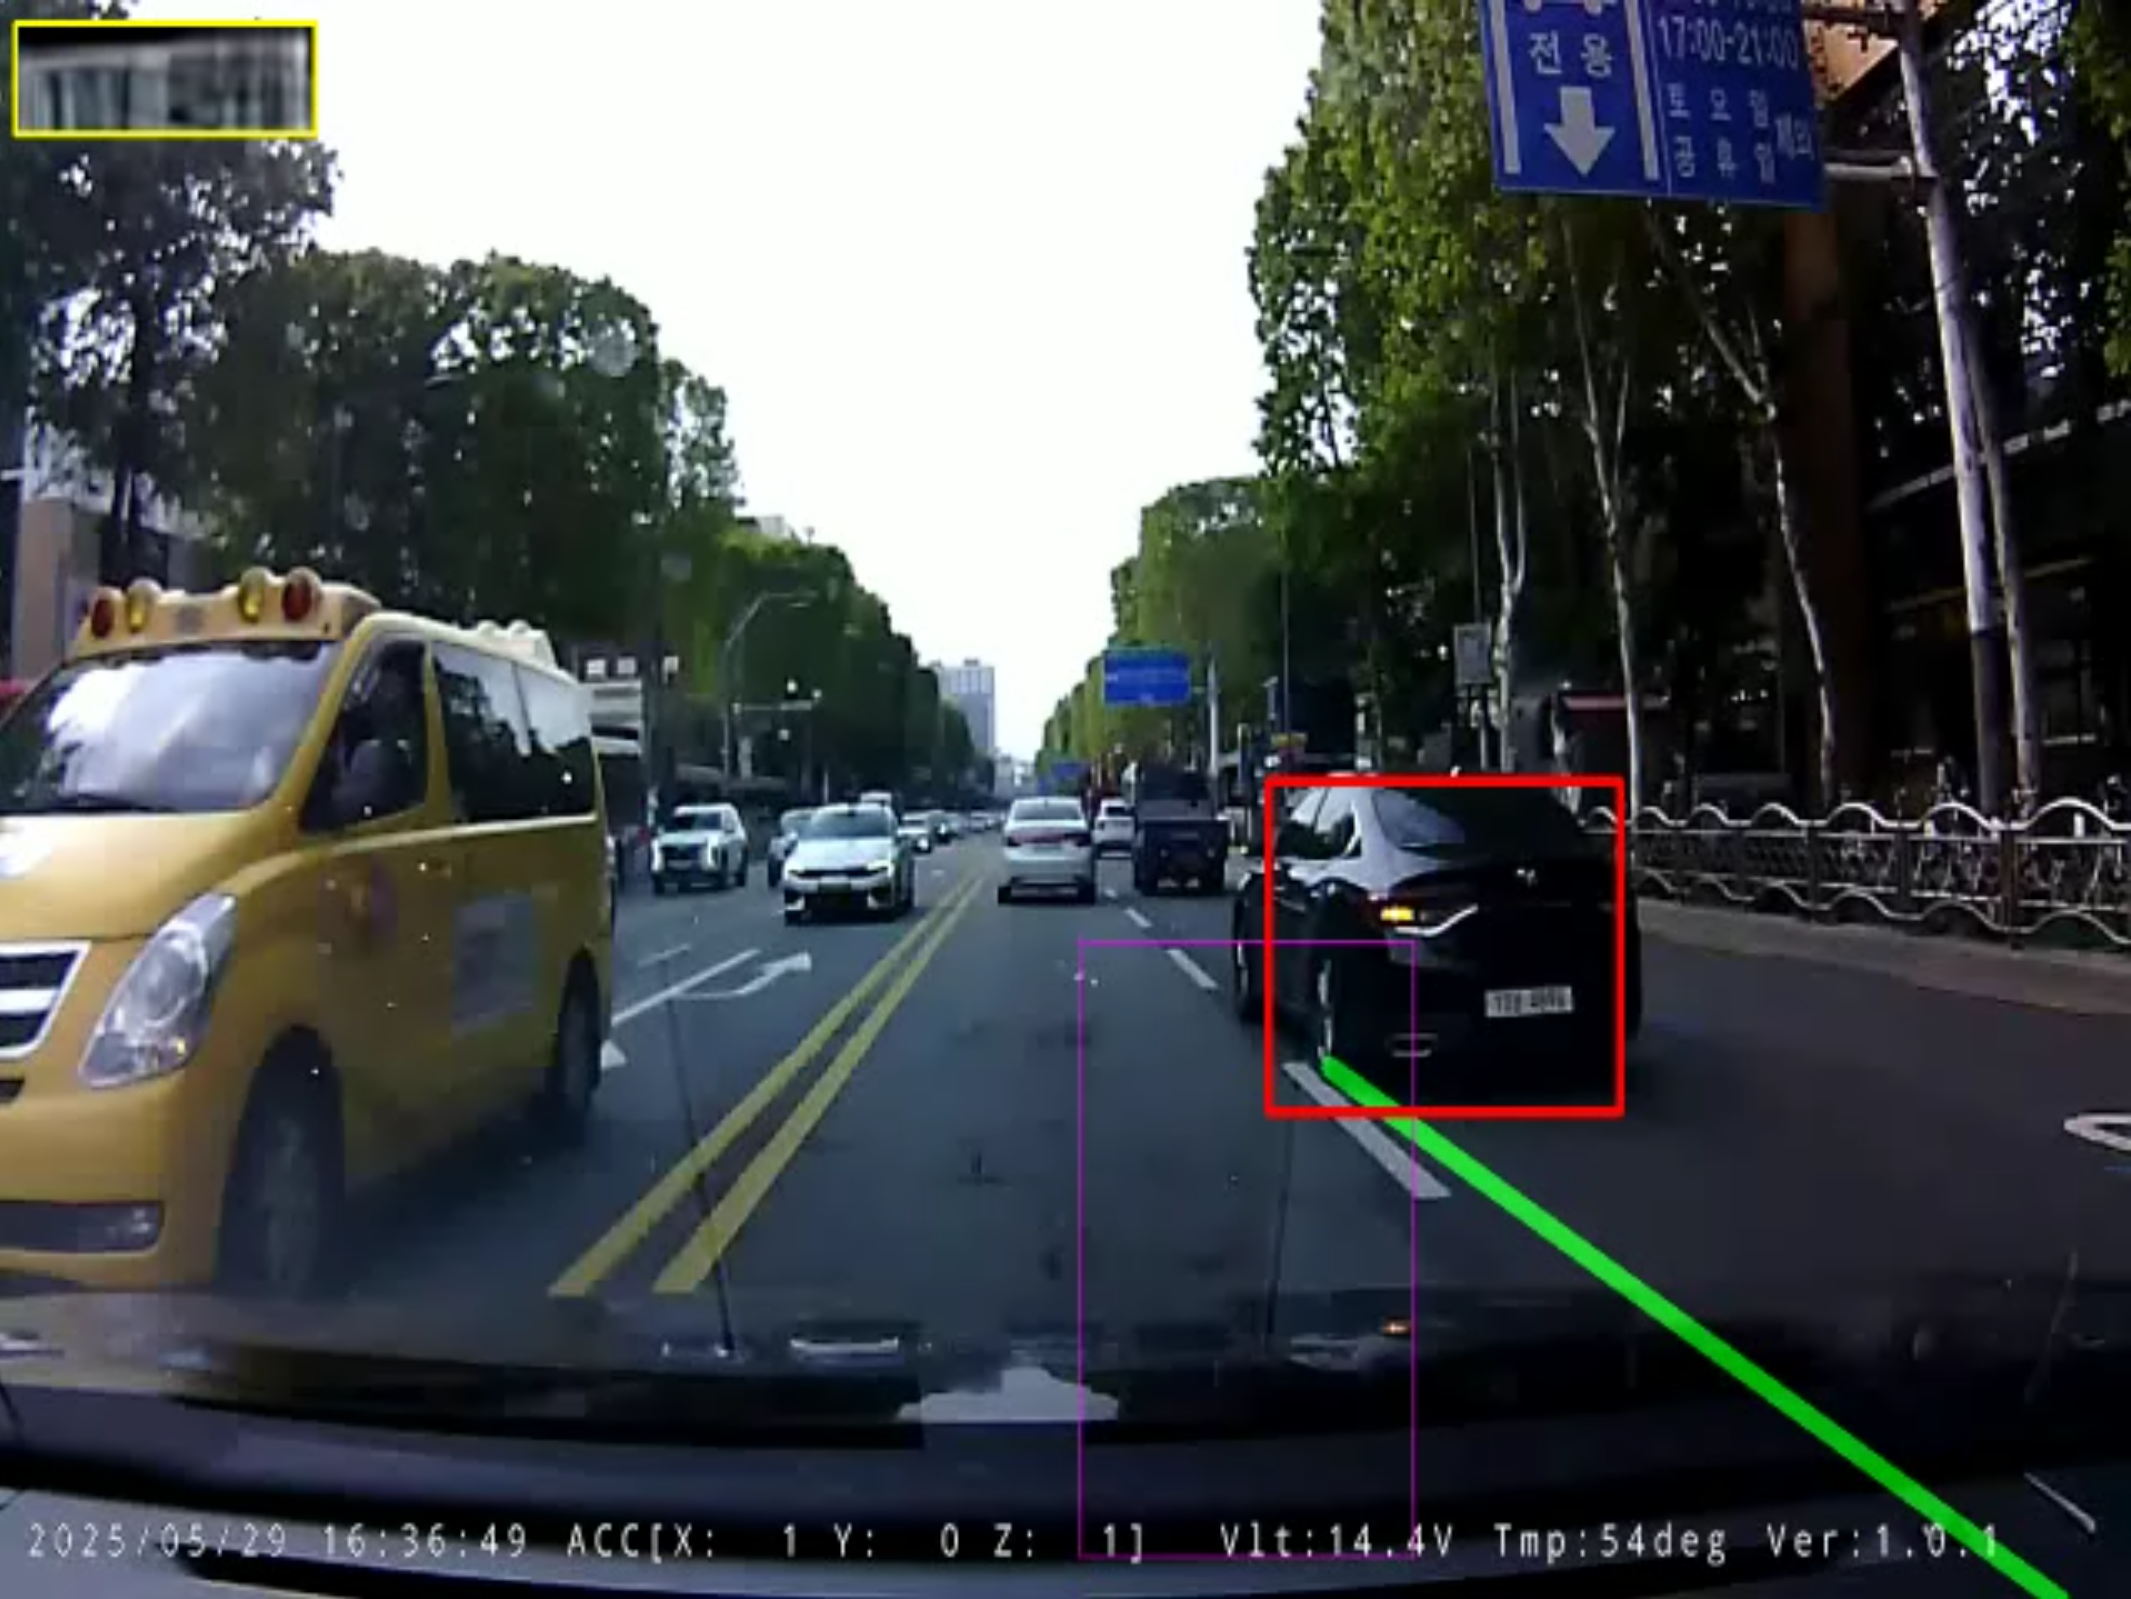
Our log.txt preserves the raw chronological milestones:
| Timestamp | Raw Plate Log | Technical Iteration & Key Breakthrough |
|---|---|---|
| 06-05 01:13 | ACCIIXOY-1Z01V1t145V... | v01: Unconstrained full-frame OCR. Road textures misinterpreted as text |
| 06-06 00:13 | fa이, ealan, cai | v04: YOLOv3 vehicle bounding box integration |
| 06-06 01:40 | 64115114, 16416114 | v07: Dedicated YOLOv5 plate detector crops plate ROI |
| 06-06 16:35 | 64아1511 -> 64가1511 | v09: EDSR_x4 deep super-resolution resolves Hangul stroke |
| 06-07 01:27 | 24가1511 -> 64가1511 | v10: Multi-frame image stacking cancels sensor noise |
| 06-07 18:20 | 64가1511 (Size: 370x315) | v11 Final: Temporal Majority Voting locks deterministic plate confirmation! |
4. Conclusion & Future Horizons
Across this 5-part series, we designed an end-to-end computer vision system integrating dynamic lane tracking, polygon IoU intrusion detection, hierarchical object localization, CSRT tracking, EDSR_x4 super-resolution, and temporal voting OCR. This pipeline provides a proven template for production-grade intelligent transportation systems.