[Webots Robotics] Sim-to-Real: Hardware Transfer via Arduino Uno, HC-06 Bluetooth & ArUco Vision Tracking (#5)
· 6 min read

📌 Key Takeaways (TL;DR)
- Problem: Severe computational constraints on microcontrollers (Arduino Uno ATmega328P with only 2KB SRAM), non-linear wheel slip, noisy ultrasonic sensing, and the classical Reality Gap between Webots simulation physics and physical hardware.
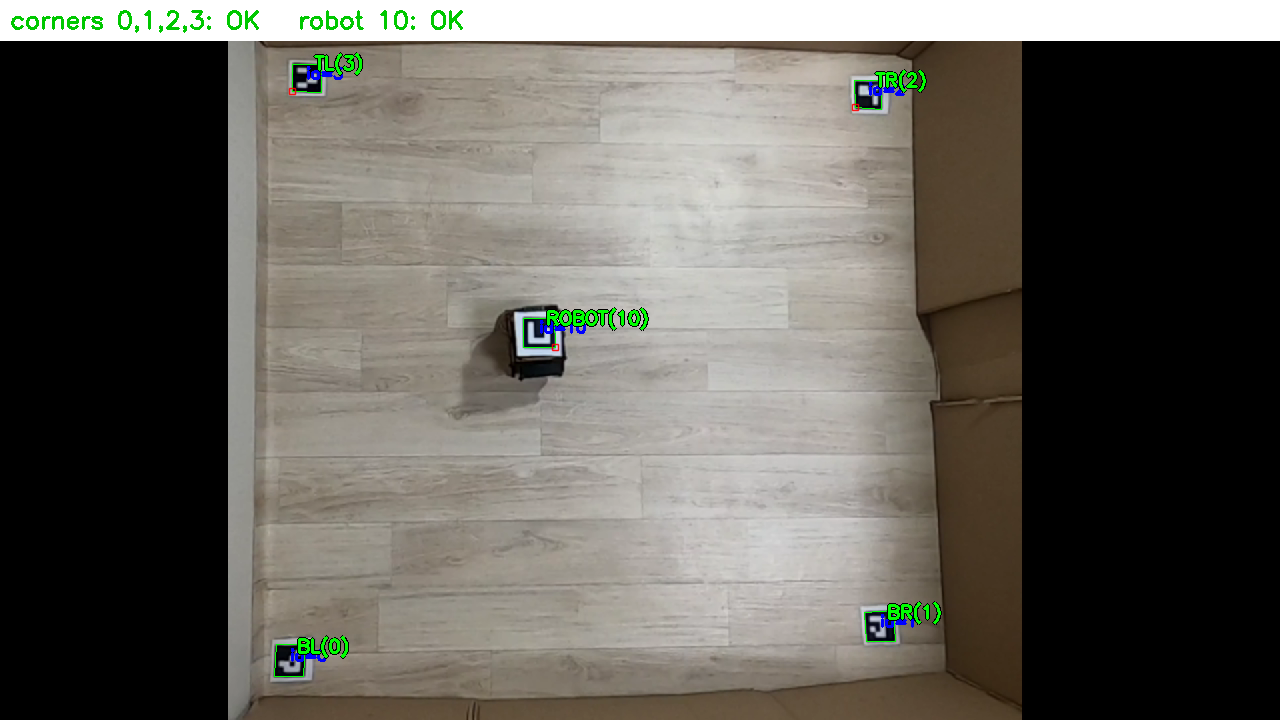
- Solution: Designed a distributed I/O architecture (HC-06 Bluetooth at 115,200 baud) where a host PC runs OpenCV vision processing and Q-Table inference while the Arduino handles low-level PWM motor actuation. Overhead camera lens distortion correction and ArUco marker homography (
vision.py) deliver sub-centimeter real-time (x, y, θ) tracking.- Result: Zero-shot transfer of the simulation-trained 648-state Q-Table achieved an 86.7% target reaching success rate (26/30 trials) in a physical 1.2m × 1.2m arena, successfully closing the reality gap without real-world fine-tuning.