[Webots Robotics] Q-Learning Autonomous Navigation: 648-Bin State Discretization & Socket Architecture (#1)
· 4 min read

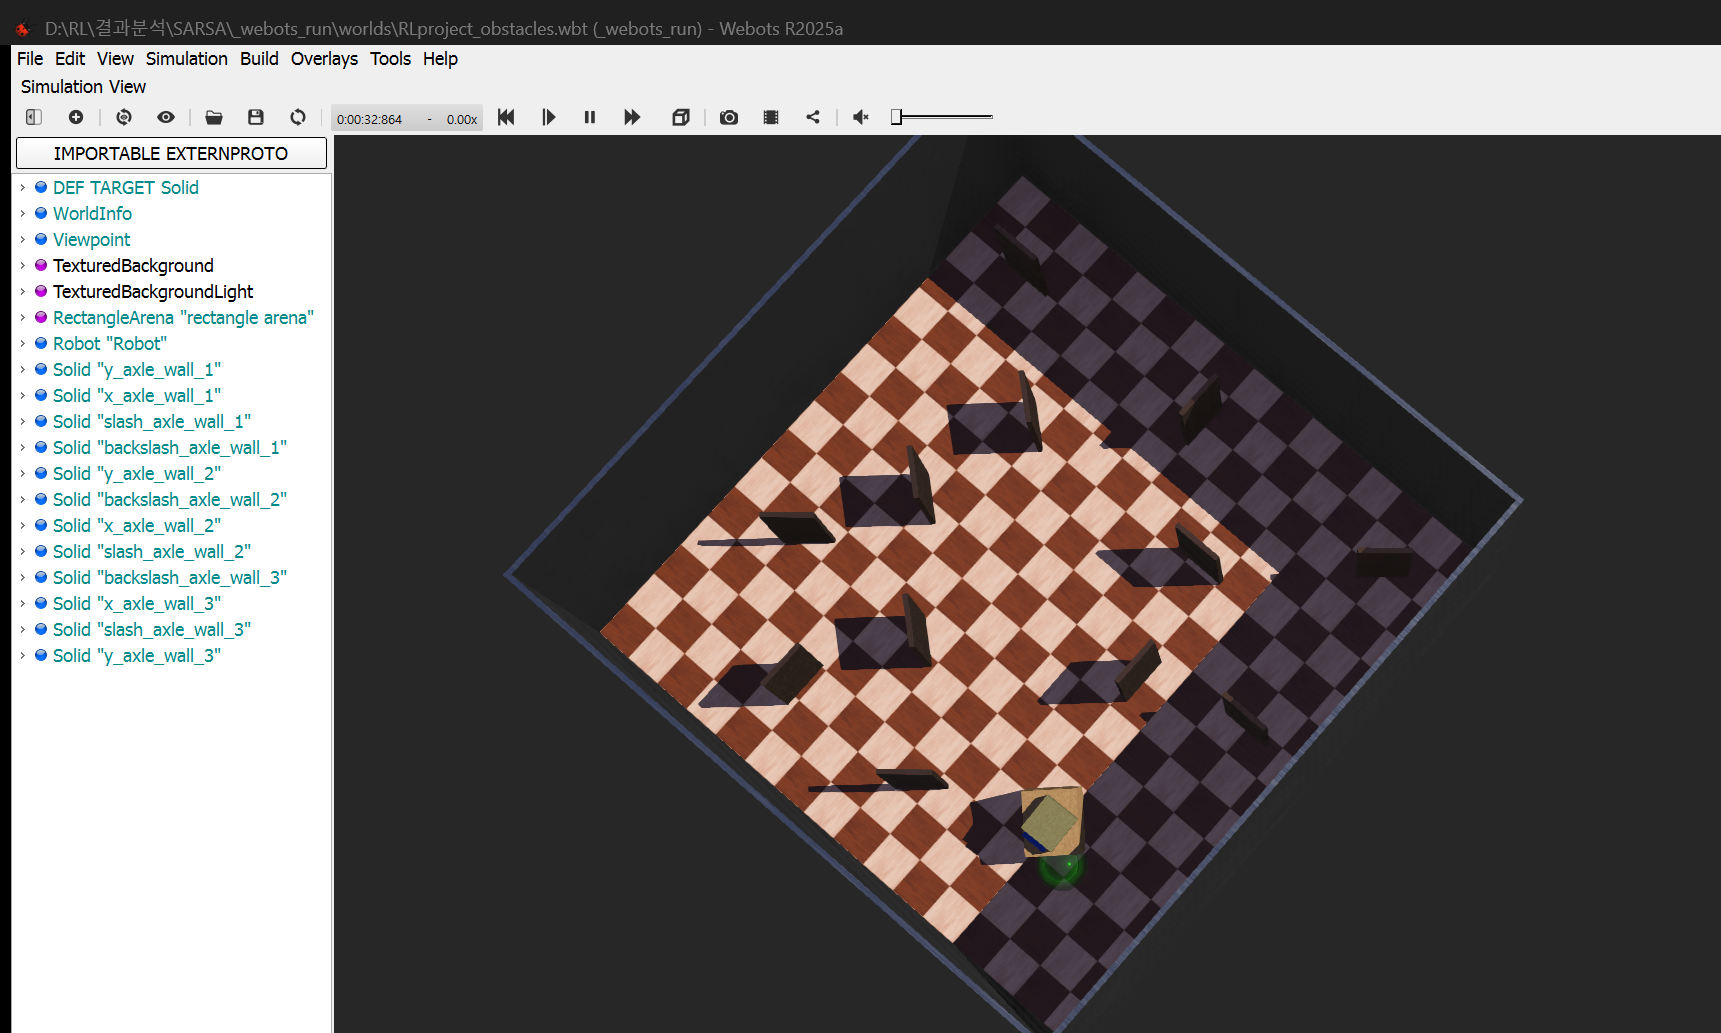
📌 Key Takeaways (TL;DR)
- Problem: Continuous sensor readings (distance & heading) cause a state-space explosion for tabular Q-learning, and synchronous IPC with the Webots simulator requires low-latency coordination.
- Solution: Designed a geometrically partitioned 5-dimensional continuous sensor mapper producing 3 × 8 × 3 × 3 × 3 = 648 discrete states (
discretizer.py) and a line-delimited JSON IPC socket pipeline over TCP port 5000.- Result: Achieved O(1) fast Q-Table indexing and reliable 32ms physics synchronization between the simulator and Python agent.