[Webots Robotics] Conquering Local Minima in 12-Wall Obstacles: Multi-Seed Headless Simulation (#3)
· 4 min read

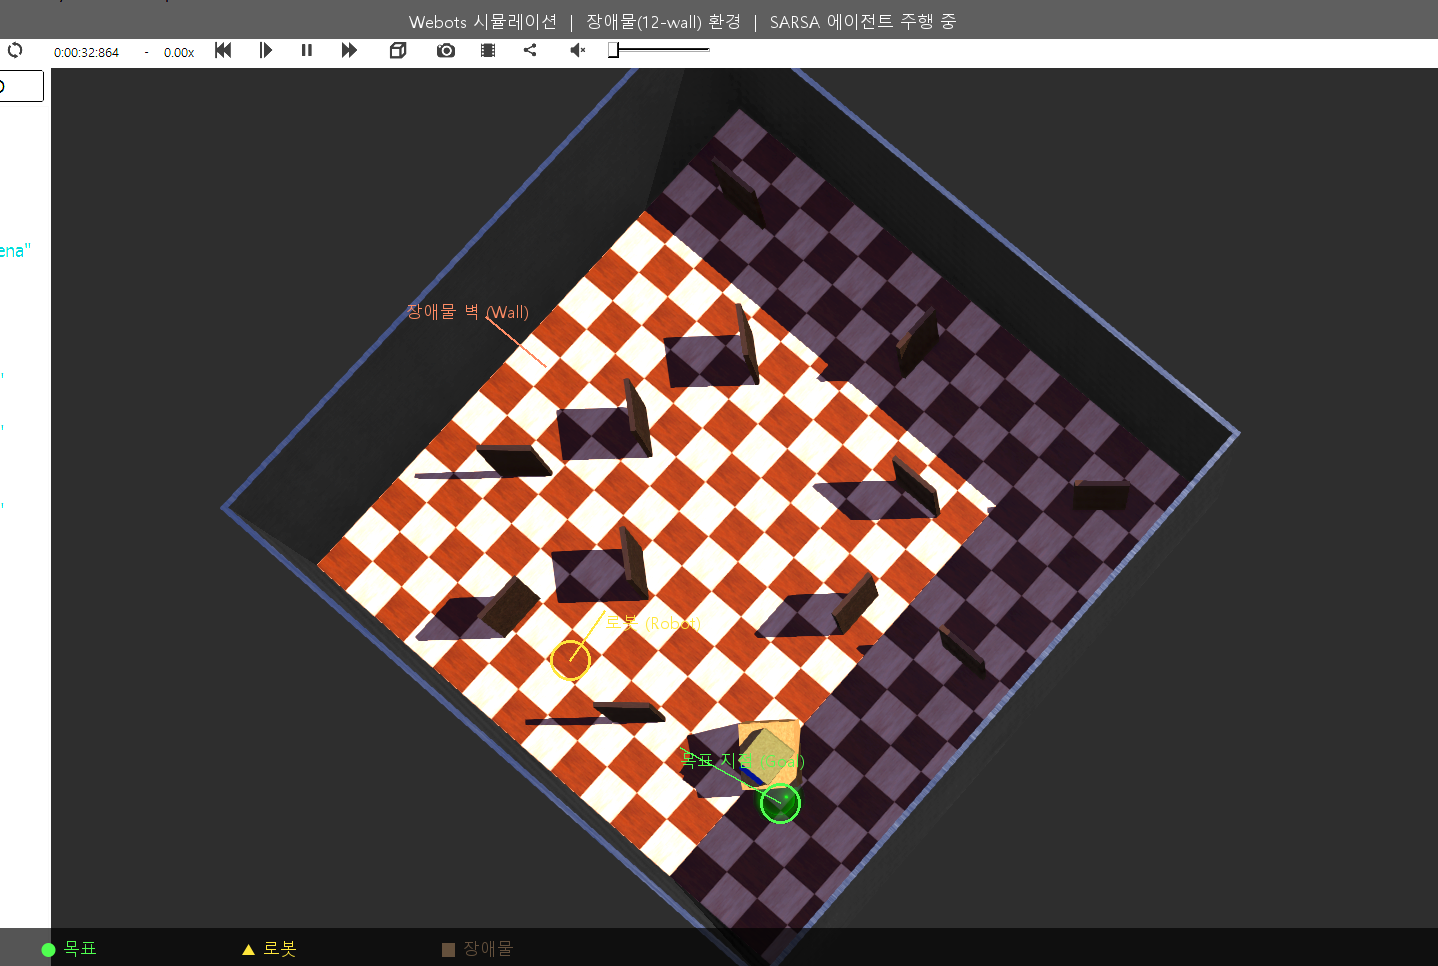
📌 Key Takeaways (TL;DR)
- Problem: When a goal lies directly behind an obstacle, the myopic nature of distance-delta rewards (+0.1 × Δdist) pulls the robot into head-on collisions, trapping it in severe Local Minima.
- Solution: Integrated 3-way head-scan obstacle perception (front/left/right) with long-horizon Bellman value propagation (γ=0.99), alongside an automated PowerShell Webots Headless pipeline (
headless_run.ps1) executing multi-seed training across seeds 0, 1, and 2.- Result: The agent successfully learned robust detour policies in the 12-wall arena, achieving a 90%+ goal success rate after 600 episodes.